Door categorieën bladeren
Ontdekken
Fiverr Pro
Nederlands
$
USD
Robots see the world through several cameras and depth sensors at once. We label your synced data so every view agrees.
SERVICES
- Labels across multiple synchronized cameras
- The same object keeps one ID in every view
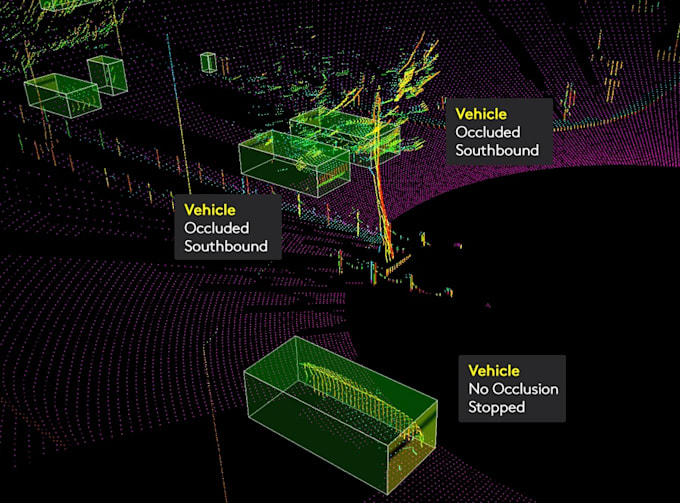
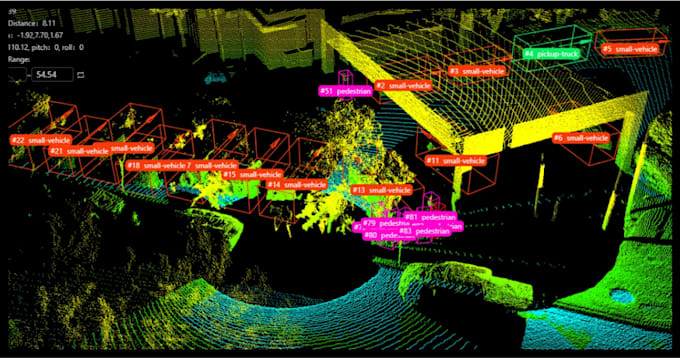
- Depth-aligned 2D and 3D boxes for RGB-D data
- Wrist camera, head camera, and fixed camera setups
DELIVERABLES
- Labels per camera plus a combined file with shared IDs
- Class and ID definition sheet
- Sync check report flagging frames with timing issues
- Preview images showing labels across views
WHY WORK WITH US
- Cross-view checks catch mismatched IDs
- Experience with robot arm and mobile robot setups
- Output in your format
- Revisions included
FREE SAMPLE
Send 5 synced frames and we'll label them free.

Techniek:
Handleiding
Type tagging:
Afbeelding
•
Video
Do you need camera calibration files?
For 3D work, yes. For 2D labels across views, they help but aren't required.
What depth formats do you accept?
PNG depth maps and NPY; ROS bags on request.
Which camera setups do you support?
Wrist, head, and fixed cameras on robot arms and mobile robots.