Door categorieën bladeren
Ontdekken
Fiverr Pro
Nederlands
$
USD
UAV- en autonome systemen-ingenieur, ArduPilot, PX4, VTOL, USV
Dronen wiegen, afdrijven, weigeren om te activeren of faalt bij de eerste vlucht? Ik zet ArduPilot- en PX4-vliegtuigen op en geef ze af zodat ze stabiel, voorspelbaar en veilig vliegen.
Ik werk met elk type: FPV- en mid-size quadcopters, zware-lift multi-rotors tot 43 inch, VTOL-quadplanes, tiltrotors, tailsitters en vliegtuigen met vaste vleugels. Recente werkzaamheden: vluchtbesturingsondersteuning voor een DARPA Lift Challenge-team en een autonome reddingsboot gebouwd vanaf nul.
WAT IK DOEN
HOE HET WERKT
100% op afstand: jij maakt verbinding met Mission Planner of QGroundControl en deelt jouw scherm. Ik kan meedoen aan een live videovergadering voor jouw eerste hovering of overgang.
JIJ ONTVANGT
Een getest parametersbestand, een kort rapportje over wat er is gewijzigd en waarom, en duidelijke vervolgstappen.
Hardware: Pixhawk, Cube, CUAV, Matek, SpeedyBee en meer. Stuur me een bericht met jouw frame, flight controller en probleem voordat je bestelt.



Automatische vertaling
Kun je op afstand aan mijn drone werken?
Ja. Ik verbind via Zoom of AnyDesk terwijl jouw flight controller is aangesloten op jouw PC met Mission Planner of QGroundControl, en ik begeleid je live tijdens testvluchten.
Welk pakket moet ik kiezen?
Basic is voor één specifiek probleem dat we tijdens een gesprek kunnen oplossen. Standard is een volledige configuratie van een nieuw of rommelig bouwwerk. Premium voegt afstelling toe aan basis van jouw vluchtlogboeken, ideaal voor zwaardere drones en VTOL-overgangen. Niet zeker? Stuur me eerst een bericht.
Wat heb je van mij nodig om te beginnen?
Het type en de maat van jouw frame, flight controller, firmwareversie en een korte beschrijving van het probleem. Als de drone heeft gevlogen, stuur dan de .bin of .ulg log en je parameterbestand. Foto's van de bedrading helpen enorm.
Stem je ook VTOL-overgangen en fixed-wing vliegtuigen af?
Ja. Ik stem quadplane, tiltrotor en tailsitter-overgangen af (airspeed, Q_assist, back-transition) en fixed-wing TECS, roll/pitch en navigatie, gebruik mijn logs en SITL eerst zodat de daadwerkelijke vlucht geen gok is.
Wat als mijn drone na levering nog steeds problemen heeft?
Stuur me het nieuwe logbestand. Als de oorzaak mijn setup of afstelling is, los ik het op tijdens jouw revisies. Is het hardware (motor, trillingsbevestiging, propellers, bedrading), dan wijs ik je precies aan wat je moet veranderen.
| (3) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |

bouizdouzeneabd

Marokko
Achraf delivered well-documented code and a detailed technical report for our Jetson Nano and ArduPilot precision-landing project. The AprilTag workflow, MAVLink integration details, and clear testing instructions made the handover practical and easy to follow. Very satisfied with the quality and attention to detail.
US$ 50
Prijs
1 dag
Looptijd

user79807411

Frankrijk
Excellent work and very professional freelancer. The communication was clear and efficient throughout the project. The final result exceeded my expectations in terms of quality and accuracy. The documentation was well structured and easy to understand. I highly recommend working with this freelancer and will definitely collaborate again in the future.
US$ 100-US$ 200
Prijs
1 dag
Looptijd

inenger

Tsjechië
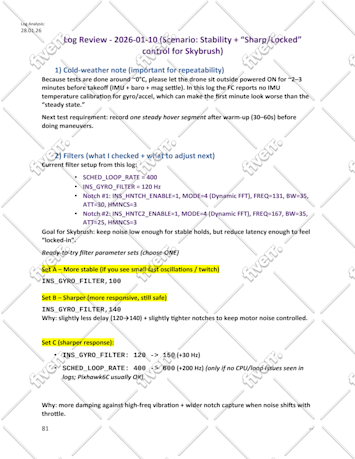
Working with Achraf exceeded my expectations. He is an absolute professional in his field who knows exactly what he is doing. He helped me tune the drone to absolute perfection, and the entire process was fast, efficient, and precise. He documents everything thoroughly, explains things clearly, and provides...
US$ 100-US$ 200
Prijs
2 maanden geleden
Looptijd
| (3) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |
bouizdouzeneabd
Marokko
Achraf delivered well-documented code and a detailed technical report for our Jetson Nano and ArduPilot precision-landing project. The AprilTag workflow, MAVLink integration details, and clear testing instructions made the handover practical and easy to follow. Very satisfied with the quality and attention to detail.
US$ 50
Prijs
1 dag
Looptijd
user79807411
Frankrijk
Excellent work and very professional freelancer. The communication was clear and efficient throughout the project. The final result exceeded my expectations in terms of quality and accuracy. The documentation was well structured and easy to understand. I highly recommend working with this freelancer and will definitely collaborate again in the future.
US$ 100-US$ 200
Prijs
1 dag
Looptijd
inenger
Tsjechië
Working with Achraf exceeded my expectations. He is an absolute professional in his field who knows exactly what he is doing. He helped me tune the drone to absolute perfection, and the entire process was fast, efficient, and precise. He documents everything thoroughly, explains things clearly, and provides...
US$ 100-US$ 200
Prijs
2 maanden geleden
Looptijd