Door categorieën bladeren
Ontdekken
Fiverr Pro
Nederlands
$
USD
Freelance Robotics ROS2 Developer
Skills
Bekijk mijn diensten
Freelance
Freelance • 3 yrs 8 mos
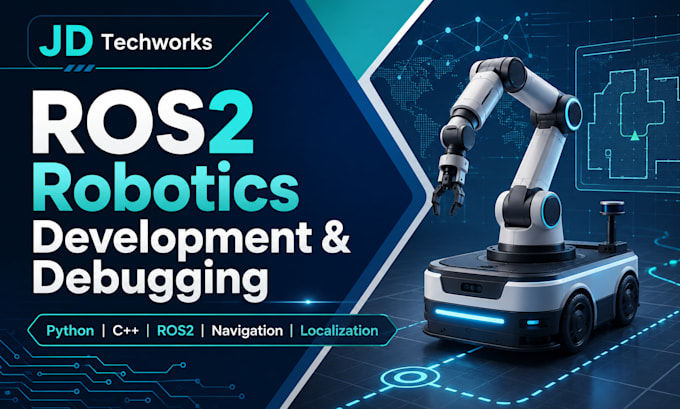
Freelance Robotics & ROS2 Developer
Jan 2025 - Present • 1 yr 9 mos
Developing a mobile robot navigation system using coarse maps and hand-drawn floor plans. Working with ROS2 and Python for mobile robotics software development. Focus areas include localization, path planning, autonomous navigation, and simulation-based evaluation using Habitat-Sim. Built practical experience with robot navigation, motion planning, and autonomous robotic systems.
ROS2-Based Mobile Robotics and Motion Control Developer
Jan 2023 - Dec 2024 • 1 yr 11 mos
Developed ROS2-based mobile robot modules using Python and C++. Worked with robot communication and motion-control functionality. Applied PID control, trajectory following, and sensor-based movement correction. Tested and debugged ROS2 robot behavior, communication, and motion-control functions. Documented robot setup, testing procedures, and observed system behavior.
