Sommige informatie wordt in het Engels weergegeven.
Over mij
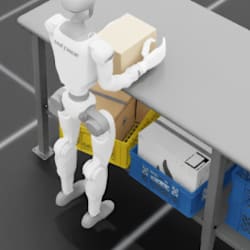
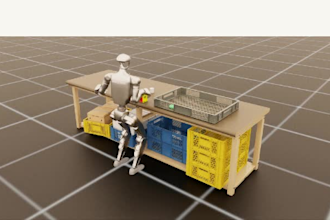
I’m a Simulation Platform Development Specialist focused on embodied AI robot simulation. I build Isaac Sim platforms for humanoid robots and dexterous hands, and create automated synthetic data pipelines.
I apply domain randomization to generate high-fidelity simulation datasets, exporting LeRobot-compatible HDF5 trajectory data for imitation learning, grasping and navigation policy training.
My services cover scene setup, URDF/USD conversion, sensor noise randomization, IK solving, and WBC / MPC controller tuning for robot algorithm development and validation.... Lees meer